I've spent six years handling motion-component orders for industrial machine builders. In my first year on the job (2019), I was convinced that the right answer to nearly every application question was "servo." That conviction cost me roughly $14,000 in wrong orders, wasted machining time, and a few humbling phone calls before I built a proper selection checklist.
So when someone asks me what's a stepper motor, or whether a gear motor will do, I don't jump to a datasheet. I walk through the dimensions that actually matter on the shop floor.
Here's the framework I use to compare servo motors against stepper motors: torque across speed, positioning behavior, control complexity, and total project cost. I'll also bring up gear motors, because they're the option people forget when they've decided they "need" precision motion control.
The Short Definitions First
What's a stepper motor?
A stepper motor is a brushless motor that divides a full rotation into fixed steps. A typical two-phase stepper has 200 full steps per revolution, which works out to 1.8 degrees per step. It doesn't need an encoder to know where it is, because the driver counts the pulses it sends. That's why steppers are called open-loop motors: no feedback, just commanded steps.
What's a servo motor?
An industrial servo motor is usually a permanent-magnet motor paired with an encoder and a dedicated servo drive. The drive constantly compares the commanded position or speed with the actual value from the encoder and corrects the current. It's a closed-loop system, which is the key difference.
The "Servo Motor Arduino" Ambiguity
When people search for "servo motor arduino," they're often thinking of a hobby RC servo: a small DC motor with a gear train and a potentiometer inside, controlled by a PWM signal. That's a completely different animal from an industrial servo motor + drive package. A hobby servo is a fine weekend project. An industrial servo is a machine component that expects a 24V or 230V/400V drive, proper tuning, and often a safety circuit. The words overlap more than the hardware does.
Where the Gear Motor Fits
A gear motor is usually an AC or DC motor with an integral reduction gearbox. It gives you continuous rotation at a fixed speed range, with much higher output torque than the bare motor could produce. You don't use it for precise positioning; you use it when the job is moving something continuously, like a conveyor, a pump, or a mixer.
Dimension 1: Torque Across the Speed Range
This is the dimension that trips up most people, and it's where I made my first expensive error. A stepper motor's torque is highest near zero speed and then drops off quickly as speed increases. Winding inductance limits how fast the current can build, so by a few hundred RPM the available torque can be half of the holding torque. By 1,000 RPM, many steppers are struggling.
A servo system is different. The drive controls current actively, so a servo motor delivers roughly its rated torque from standstill up to its rated speed. That's a massive practical difference for any axis that needs to move fast under load.
My mistake in 2019 was selecting a NEMA 34 stepper based on its holding torque for an indexing operation that reached about 1,100 RPM. The motor didn't fail instantly—it lost steps slowly, the axis drifted, and the tool path was off by a few millimeters. That cost me $890 in scrap and a three-day delay.
If the dimension that matters most to you is speed under load, the conclusion is clear: choose a servo, not a stepper. If your machine runs mostly at low RPM and needs high torque at standstill, a stepper can still be the smarter choice.
Dimension 2: Positioning and Holding
A stepper knows where it should be, but it doesn't know where it actually is. If the load exceeds the available torque—during a rapid acceleration, a jam, or a feed-rate spike—the motor can miss steps silently. No alarm sounds. The machine just ends up in the wrong position.
A servo system detects that problem. The drive sees the following error and can trigger an alarm, stop the axis, or correct in real time. That's a genuine safety advantage in applications where a missed step could mean a crash.
But here's the conclusion people don't expect: servos aren't automatically better at holding a stationary axis. A stepper with full phase current applied will hold its position very stiffly at standstill. A servo can hold position too, but only while the drive is active and current is flowing. If someone hits an E-stop and the drive drops out, the axis is free to move unless it has a mechanical brake. In fall 2022, I specified a servo without a brake on a vertical lift because I was trying to protect the budget. The drive held the axis during normal operation, but during a power-loss test, the carriage dropped about 100 mm before it hit a mechanical stop. No one got hurt, but the tooling didn't survive. The lesson now lives in our checklist: vertical axes get a brake, regardless of motor type.
Dimension 3: Getting It Running With an Arduino, PLC, or Drive
This dimension is where the romantic idea of a servo dies for many people. A stepper is wonderfully simple to drive. An Arduino, PLC, or motion controller sends step and direction pulses to a stepper driver, and the driver handles the current. If you know how to send pulses, you can get a stepper moving in an afternoon.
An industrial servo is not a plug-and-play device. You need the right servo drive, matching encoder feedback, proper power supply, tuning parameters, and usually a configuration tool. There's a learning curve that has nothing to do with the motor itself.
So if you're building a small machine and wondering whether to use a servo motor with Arduino, my honest answer is: start with a stepper. A NEMA 17 or NEMA 23 stepper paired with a basic driver is well within Arduino territory, and it will teach you real motion-control fundamentals. Save the servo for when you actually need the closed-loop performance.
And if you don't need positioning at all—if the shaft just needs to spin continuously—then neither a stepper nor a servo belongs in the conversation. A gear motor, or a standard AC motor with a VFD, will do the job at a fraction of the cost and complexity.
Dimension 4: Total Project Cost
A quality NEMA 23 stepper with a decent driver can land somewhere in the $80 to $150 range, depending on the driver features. A matching 400W industrial servo motor and drive package is often $400 to $900 or more. For multi-axis machines, the difference adds up quickly.
But the lowest purchase price isn't the lowest total cost. A stepper running at high speed may oversize the motor to get enough torque, or waste energy as heat. A servo system that prevents missed steps and crashes can pay for itself in a week. The decision comes back to the application, not the component price tag.
Here's where I also learned an adjacent lesson: the components around the motor matter just as much to the machine's reputation. A motor can be correctly sized, but if the rest of the system is underspecified, the customer still sees a failure.
One Failure That Had Nothing to Do With the Motor
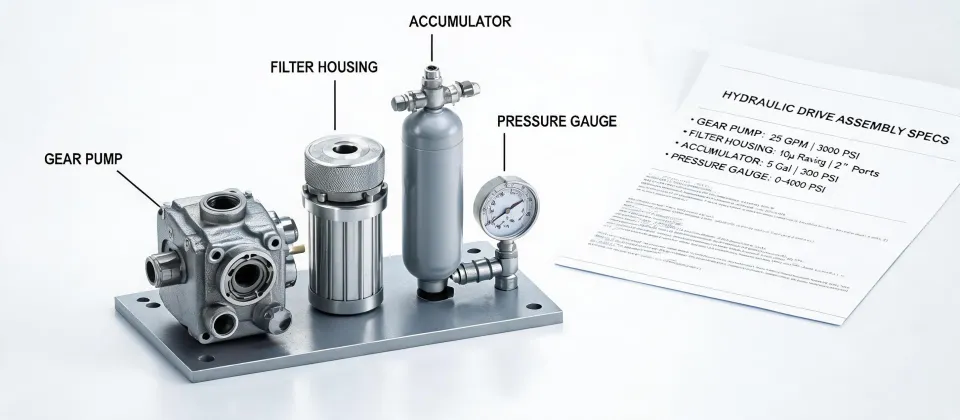
In early 2023, we helped build a small hydraulic test stand. The drive was a straightforward gearmotor—no stepper, no servo, no positioning loops. The motor choice was correct. The failure came from something far less glamorous: the filter.
The design specified a genuine HYDAC filter, but a shortcut was taken during purchasing and a no-name element was installed instead. The thread fit, so everyone moved on. Around 200 operating hours later, the pump got noisy and inspection showed contamination damage. The fluid was clean when it went in; the filter media simply didn't do what the originally specified element would have done.
I'm not a filtration engineer, so I won't pretend to explain the complexities of filter media design. What I can tell you from an application-engineering perspective is this: when we finally compared the components side by side, the difference was clear. The genuine HYDAC filter had an identifiable part number, consistent marking, and performance data that we could look up. The no-name replacement had none of that. Checking the HYDAC logo and matching the part number in the HYDAC filter catalog became a standard step on our pre-install checklist.
The cheap element probably saved $30. The contamination damage cost roughly $2,400 plus downtime and a difficult conversation with the customer. Industrial equipment is a visual and physical representation of your engineering judgment. Quality perception is brand perception, whether we're talking about a motor, a gearbox, or a filter canister.
How I Choose After All This
If you want a simple "which one wins" answer, I can't give you one, because the right choice depends on the machine's actual job. Here are the scenarios I use when I'm talking through a decision:
- Low-speed positioning with modest budget: stepper motor. It holds well, it's easy to control, and the open-loop risk is manageable when loads are predictable.
- High-speed motion, variable loads, or safety-critical positioning: servo motor. The closed-loop feedback and stall detection are worth the extra cost.
- Continuous rotation with torque at a fixed speed: gear motor. Don't over-engineer a positioning motor into a job that just needs to spin.
- Hydraulic systems: pay as much attention to the filter and fluid care as to the pump and motor. This is where genuine components and traceability matter most.
The common thread in my own mistakes was choosing based on what sounded impressive rather than what the application required. A wrong motor doesn't feel like a wrong choice to the customer; it feels like a defective machine. The fix isn't to default to the most expensive option. It's to compare the right dimensions first, and to remember that a machine is judged by every component on it.